



What «eyes» do you give an autonomous vehicle when every centimetre counts?
At CYP Core we have kicked off the TECHDUAL project. Our end goal is an intelligent detection system, but the first step is critical: choosing the hardware.
A UGV (unmanned ground vehicle) poses a unique integration challenge. We cannot fit just any camera. We are running a thorough study to choose the right combination of:
- thermal cameras;
- night vision;
- optical sensors.
The criterion? The highest resolution and sensitivity in the smallest possible size.
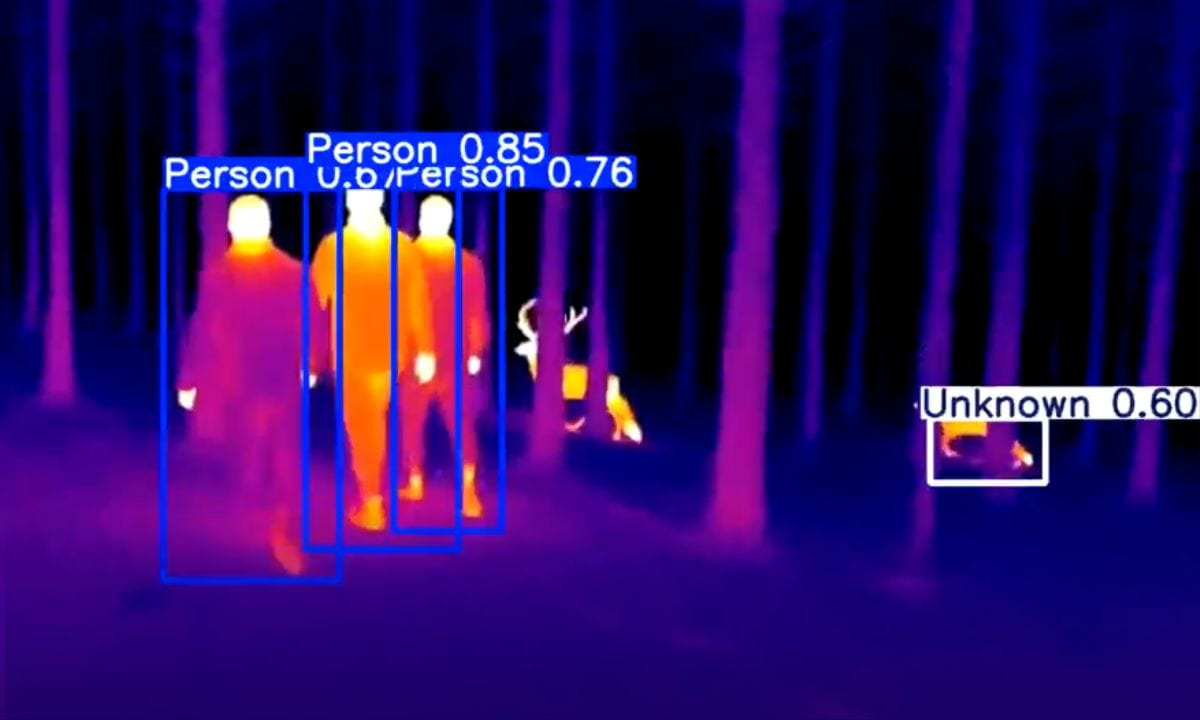
We have already run the first proofs of concept on some test videos, and the preliminary detection results are promising. We are defining the architecture that will let the vehicle «see» without compromising its mobility or overloading its structure.
The journey towards on-board artificial vision begins.
The project also involves CIAC (the Catalan automotive cluster), FACYL (the automotive and mobility cluster of Castilla y León), the Automotive and Mobility Cluster of Aragón, CEAGA (the automotive and mobility cluster of Galicia), AVIA (the automotive and mobility cluster), INERTIM Research and Optare Solutions.
Original post
Who did the work